


- CTI
- SHINKAWA
- SEL
- ADLINK
- Jaquet
- ETEL
- Basler Electric
- Beckhoff
- DEIF
- SAUTER
- UNIOP
- Sieger
- Autronica
- SAMSUNG
- Stucke Elektronik
- Moore
- NI
- EMERSON
- IBA
- SST
- LEYBELOD
- SAMSUNG
- METSO
- AMAT
- Phoenix
- LAND
- LAMBDA
- Abaco
- Kongsberg
- ALFA LAVAL
- Pacific Scientific
- Others
- OMRON
- AMAT
- ICS Triplex
- Lam Research
- KUKA
- Hirschmann
- ELAU
- EATON
- Applicom
- Watlow Anafaze
- Meggitt Vibro-meter
- Carrier
- Other
- ROCKWELL
- Rolls-Royce
- SAACKE
- Yokogawa
- B&R
- Reliance Electric
- Seifert
- A-B
- Weimeide Metso
- KEBA
- HIMatrix
- Valmet
- Schneider
- Prosoft
- PEPPERL+FUCHS
- Honeywell
- Woodward
- GE
- GEA Westfalia Separator
- Bently Nevada
- ALSTOM
- Foxboro
- MOTOROLA
- Fanuc
- VMIC
- KOLLMORGEN
- SEW
- Rexroth
- AEROTECH
- TOSHIBA
- TmeIC
- Sumitomo
- SOCAPEL SOCASIN
- SMC
- Stromag
- SIEMENS
- SCHUMACHER
- ABB
- MOOG
- EPRO
- EMERSON
- Triconex
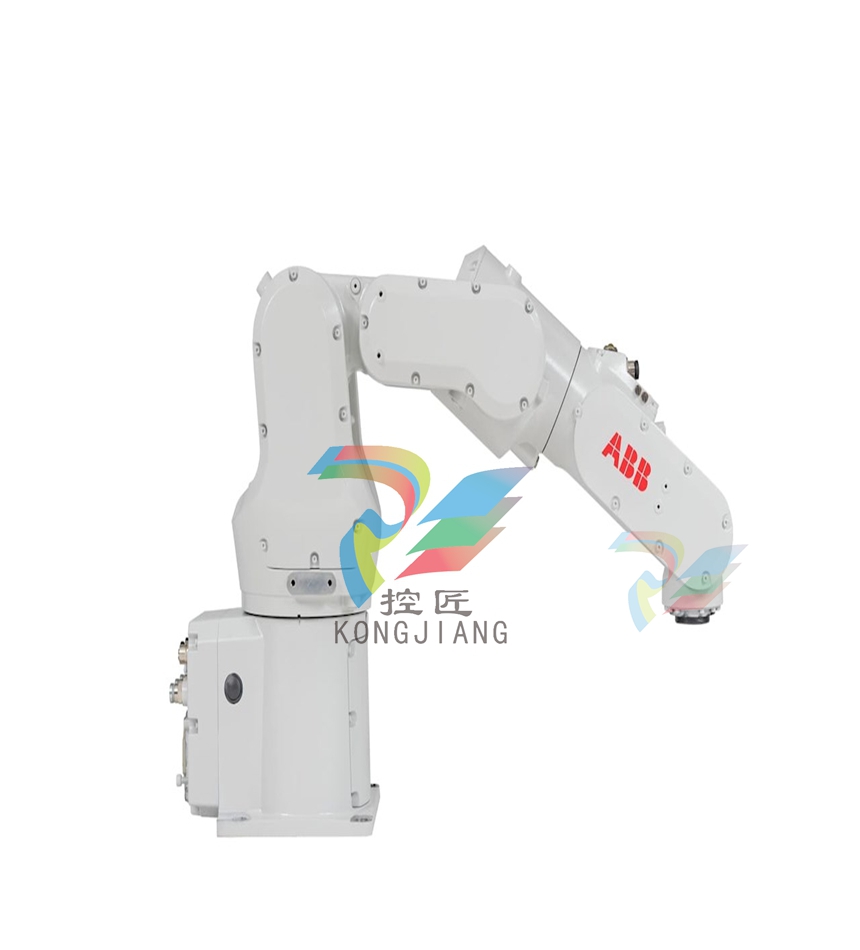
ABB ACU-01B 3HNA024871-001 Robot controller
Robot controller is a device that controls the robot to complete certain actions or tasks according to instructions and sensing information. It is the heart of the robot and determines the performance of the robot. From the processing mode of robot control algorithm, it can be divided into two structural types: serial and parallel.ABB ACU-01B 3HNA024871-001 Robot controller

Serial processing structure
The so-called serial processing structure means that the control algorithm of the robot is processed by a serial machine. For this type of controller, it can be divided into the following types according to the computer structure and control mode:
(1) Single CPU structure, centralized control mode, all control functions are realized by a powerful computer. In early robots, such as Hero-I and Robot-I, this structure was adopted, but many calculations (such as coordinate transformation) were needed in the control process, so this control structure was slow.
(2) Two-stage CPU structure and master-slave control mode. The first-stage CPU is the host, which plays the functions of system management, robot language compilation and man-machine interface. At the same time, it also uses its computing power to complete coordinate transformation and trajectory interpolation, and regularly sends the computing results to the public memory as the increment of joint motion for the second-stage CPU to read; The secondary CPU completes the digital control of all joint positions. There is basically no connection between the two CPU buses of this kind of system, and it only exchanges data through common memory, which is a loosely coupled relationship. It is very difficult to further disperse the functions by using more CPUs. The computer system of M otoma n robot (5 joints, driven by DC motor) produced in Japan in the 1970s belongs to this master-slave structure.
(3) Multi-CPU structure and distributed control mode
At present, this two-level distributed structure of upper and lower computers is widely used, and the upper computer is responsible for the whole system management, kinematics calculation, trajectory planning and so on. The lower computer is composed of multi-C PU, and each CPU controls a joint movement. These CPUs are closely coupled with the main controller through the bus, so the working speed and control performance of the controller with this structure are obviously improved. However, the common feature of these multi-CPU systems is the functional distributed structure adopted for specific problems, that is, each processor undertakes a fixed task, which is the structure of most commercial robot controllers in the world at present.
The position control part of the controller computer control system adopts digital position control almost without exception.
The above-mentioned controllers all use serial computers to calculate the robot control algorithm, and they have a common weakness: heavy calculation burden and poor real-time performance. Therefore, offline planning and feedforward compensation decoupling are mostly used to reduce the calculation burden in real-time control, and when the robot is disturbed in operation, its performance will be affected, making it more difficult to ensure the required accuracy index in high-speed movement.
Parallel processing structure
Parallel processing technology is an important and effective means to improve the calculation speed, which can meet the real-time requirements of robot control. According to the literature, the parallel algorithm of robot kinematics and dynamics and its realization are studied more. In 1982, J. Y. S. Luh first proposed the parallel processing problem of robot dynamics. This is because the dynamic equation of articulated robot is a set of nonlinear and strongly coupled second-order differential equations, and the calculation is very complicated. Improving the calculation speed of robot dynamic algorithm also lays the foundation for realizing complex control algorithms such as calculating torque method, nonlinear feedforward method and adaptive control method. One of the ways to develop parallel algorithms is to transform serial algorithms to parallelize them, and then map them to parallel structures. Generally, there are two ways: one is to consider the given parallel processor structure and develop the parallelism of the algorithms according to the computing model supported by the processor structure; The second is to develop the parallelism of the algorithm first, and then design the parallel processor structure supporting the algorithm to achieve the best parallel efficiency.

| User name | Member Level | Quantity | Specification | Purchase Date |
|---|




-
SAUTER AXT 201. 211: Thermal actuator for unit valves with stroke
-
SAUTER AXS 215S: Continuous actuator for unit valves, with stroke
-
SAUTER AXM 217S: Motorised actuator for unit valves with positioner
-
SAUTER AVM 321S, 322S: Valve actuator
-
SAUTER AVM234S: SUT valve actuator with positioner
-
SAUTER AVM 105. 115: Valve actuator
-
SAUTER AVF234S: SUT valve actuator with spring return
-
SAUTER AVF 124: Actuator with spring return
-
SAUTER AKM115SAF332: Smart Actuator for ball valve, BACnet/IP
-
SAUTER AKM115SA: Smart Actuator for ball valve
-
SAUTER AKM105S, 115S: Rotary actuator with SAUTER Universal
-
SAUTER AKM 105. 115: Rotary actuator for ball valve
-
SAUTER AVM234S: SUT valve actuator with positioner
-
SEL SEL-T401L Ultra-High-Speed Line Relay
-
SEL-SEL-T400L Time-Domain Line Protection
-
SEL SEL-2664S Stator Ground Protection Relay
-
SEL-787-2/-3/-4 Transformer Protection Relay
-
SEL SEL-787 Transformer Protection Relay
-
SEL SEL-751 Feeder Protection Relay
-
SEL SEL-700G Generator Protection Relay
-
SEL-SEL-487E Transformer Protection Relay
-
SEL-SEL-400G Advanced Generator Protection System
-
SEL SEL-387E Current Differential and Voltage Relay
-
SEL-387A Current Differential and Overcurrent Relay
-
SEL SEL-387 Current Differential and Overcurrent Relay
-
SEL SEL-300G Generator Relay
-
SEL SEL-700BT Motor Bus Transfer Relay
-
CTI 2500 Series® Slice Ethernet Remote I/O System
-
CTI 500 Series® Compact Programmable Automation Control System
-
CTI 2500 Series® Classic Programmable Automation Control System
-
CTI 2500 Series® Bases
-
SHINKAWA VM-25 Condition Monitoring System UPDATED
-
SHINKAWA VM-5 SERIES OPTIONS
-
ABB SACO 64D4 Annunciator unit
-
ABB SPAU 140 C Synchro-check relay
-
HONEYWELL TDC 3000X Advanced Process Manager
-
HONEYWELL ENHANCED MICRO TDC 3000
-
VIBRO-METER VM600Mk2/ VM600 XMx16 + XIO16T extended condition monitoring modules
-
VIBRO-METER VM600Mk2/ VM600 RPS6U rack power supplies
-
VIBRO-METER VM600Mk2/ VM600 ABE056 slimline rack
-
VIBRO-METER VM600Mk2 RLC16Mk2 relay modules
-
VIBRO-METER VM600Mk2 MPC4Mk2 + IOC4Mk2 machinery protection and condition monitoring modules
-
VIBRO-METER VM600Mk2 CPUMMk2 + IOCNMk2 rack controller and communications interface module
-
VIBRO-METER VM600Mk2 CPUMMk2 + IOCNMk2 rack controller and communications interface module
-
ADLINK cPCI-8168 Advanced 6U CompactPCI 8-axis Motion Controller with One HSL Network
-
ADLINK PCI/PCIe-7300A, cPCI-7300 32-CH 80 MB/s High-Speed Digital I/O Cards
-
ADLINK cPCI-7248/7249R 48-CH DIO & Timer/Counter Cards
-
ADLINK PCI-7230/7233/7234. LPCI/LPCIe/cPCI-7230 32-CH Isolated DIO Cards
-
ADLINK cPCI-6965 Series Value 6U CompactPCI® Intel® Core™2 Duo
-
ADLINK cPCI-6910 Series 6U CompactPCI® Dual-Core Intel® Xeon® Processor LV / ULV Universal Blade
-
ADLINK CPCI-6670 6U CompactPCI Low Power Pentium® III SBC
-
ADLINK cPCI-6625/6 Series6U CompactPCI® PlusIO blade with Intel® Core™ i7/i3 Processor
-
ADLINK 3U CompactPCI CPU Modules
-
ADLINK CM-435 Extreme Rugged™ PC/104 Single Board Computer
-
ADLINK Centralized Motion Controllers PCI-8254/8258
-
ADLINK NuPRO-E43 PICMG® 1.3 Full-Size LGA1151 with 6th/7th Generation Intel® Core™ i7/i5/i3o
-
ADLINK DLAP-211-JNX/DLAP-211-JT2/ DLAP-211-Nano
-
نظام التحكم الرقمي في التحفيز الكهربائي BASLER DECS-200
-
Hirschmann RS30-1602O6O6SDAE compact OpenRail managed Ethernet switches
-
Hirschmann RS30-0802O6O6SDAE Ethernet switch
-
Hirschmann RS20-1600T1T1SDAE Management-type Ethernet switch
-
Hirschmann OCTOPUS 24M Limited Availability/Passive
-
Hirschmann MSP30-24040SCZ9MRHHE3A
-
Hirschmann MAR1040-4C4C4C4C9999SMMHRHHXX.X. Gigabit Ethernet Switch configurator
-
Hirschmann Industrial Ethernet Rail Switch SPIDER II, SPIDER II Giga, SPIDER II PoE
-
Hirschmann Industrial Ethernet Firewall EAGLE One
-
Hirschmann Industrial Security Router EAGLE20/30
-
Hirschmann Description and operating instructions RS2-xTX/xFX EEC
-
Basler Electric DIGITAL EXCITATION CONTROL SYSTEM DECS-300
-
Basler Electric DECS-200 Digital Excitation Control System
-
Basler Electric GENERATOR PROTECTION SYSTEM BE1-GPS100
-
Jaquet FT3000 Speed measurement system
-
Hirschmann Industrial Ethernet Ruggedized Switch MACH1000 Family
-
Basler Electric BESTCOMSPlus®
-
ETEL AccurET MODULAR 300 EA-P2M-300-xxxxxA controller
-
Basler Electric ES Series Protection Relays
-
ABB Multifunction Protection and Switchbay Control Unit REF542plus
-
EMERSON AMS 2140 Machinery Health Analyzer
-
Hirschmann Industrial Ethernet Rail Switch RS20 Basic Family
-
GE Grid Solutions P40U Px40 USB Adaptor
-
ABB ontinuous Gas Analyzers AO2000 Series AO2040CU Ex Central Unit in Category 2G
-
ABB Advance Optima AO2000 Series Continuous gas analyzers Models AO2020. AO2040
-
ABB Advance Optima Module Uras 14
-
SAACKE control optimization
-
SAACKE se@vis efficiency monitor
-
SAACKE se@vis pro
-
SAACKE se@vis eco
-
SAACKE se@vis compact
-
HIRSCHMANN Industrial ETHERNET Switch MICE MS20/MS30
-
HIRSCHMANN MICE Media modules
-
Kongsberg GL-10 Level Switch
-
B&R ACOPOSinverter P74 frequency converter
-
Beckhoff CX2020 | Basic CPU module (service phase)
-
Beckhoff CX1010 | Basic CPU module (service phase)
-
Beckhoff CX5120 | Embedded PC with Intel Atom® E3815
-
Beckhoff CP69xx-xxxx-0010 | Economy built-in Control Panel with DVI/USB Extended interface
-
Beckhoff CP29xx-0000 | Multi-touch built-in Control Panel with DVI/USB Extended interface
-
SAACKE Monoblock Rotary Cup Burner SKVJ-M
-
ABB Plantguard Fault Tolerant Technology Architecture and Software
-
OMRON H8PR-8/H8PR-8P H8PR-16/H8PR-16P H8PR-24/H8PR-24P Rotary Positioner
-
ABB PFSA107-Z42 DTU Stressometer Digital Transmission Unit
-
Nidec Mentor MP
-
IBA PC connection for high-precision data acquisition with ibaNet-E
-
IBA FO Connection to Reflective Memory
-
IBA FO Connection to Siemens Systems
-
IBA Interface Cards For Fiber Optic Connections
-
IBA Field and Drive Buses
-
IBA ibaPADU-S Modular System
-
IBA ibaMAQS
-
STUCKE SYMAP®ARC
-
STUCKE SYMAP®R
-
STUCKE SYMAP®Compact
-
MOOG G123-825-001 BUFFER AMPLIFIER
-
Motorola MVME5100 Series VME Processor Modules
-
ABB MEASUREMENT & ANALYTICS NGC8209 Natural gas chromatograph
-
Motorola MVME162 Embedded Controller
-
HIMatrix Safety-Related Controller System Manual for the Modular Systems
-
MOTOROLA MVME2400 Series VME Processor Module
-
Sieger System 57
-
KONGSBERG MRU product line continuation
-
Woodward easYgen-3100/3200 Genset Control for Multiple Unit Operation
-
Woodward MFR 300 Multifunction Relay / Measuring
-
ABB AX410, AX411, AX416, AX450 and AX455 Single and dual input analyzers
-
Woodward easYgen-1400 Technical Manual Genset Control
-
Woodward easYgen-400 Operation Manual Genset Control
-
Woodward High Output Digital Valve Positioner (DVP) DVP5000/DVP10000/DVP12000
-
Woodward High Output Digital Valve Positioner DVP5000 and DVP10000
-
Woodward TG611-13/-17 Overspeed Test Device Conversion Kit

Add: High-tech Software Park, Xiamen City, Fujian Province
Mobile: +86-17750019513(WhatsApp)
Email: yy4291644@gmail.com
Website: https://www.abb-sis.com


-
Beckhoff CX2500-B310 | Fieldbus slave module PROFIBUS for CX20xx, CX52x0. CX53x0. CX56x0
-
Beckhoff CX2500-0070 | USB 3.0 module for CX20xx, CX52xx, CX53x0. CX56x0
-
Beckhoff CX2500-0062 | 2.5 Gbit Ethernet module for CX20xx, CX52x0. CX53x0. CX56x0
-
Beckhoff CX2500-1061 | Power over Ethernet module for CX20xx, CX52x0. CX53x0. CX56x0
-
Beckhoff CX2500-1060 | Ethernet module for CX20xx, CX52x0. CX53x0. CX56x0
